Project Overview
The NEO System is a custom, high-efficiency motor control and distributed telemetry architecture engineered specifically for endurance electric racing in the Greenpower IET Formula 24+ championship, built to operate under strict energy-efficiency and thermal constraints.
The Challenge
Greenpower IET Formula 24+ regulations enforce strict hardware limits: vehicles run on a standard 24V DC motor and a limited lead-acid battery pack.
- Energy Budgeting & Pacing: Calculating the optimal target speed in real time so the vehicle finishes the endurance heat with maximum pace without depleting the battery pack early.
- Thermal & Switching Efficiency: Minimizing $I^2R$ conduction and switching losses across the power stage under sustained 24V current loads.
- Operational Simplicity: Delivering critical, actionable feedback to both the driver inside the cockpit and race engineers on the pit wall without complicated setup procedures.
The Architecture: Distributed 2-Board CAN System
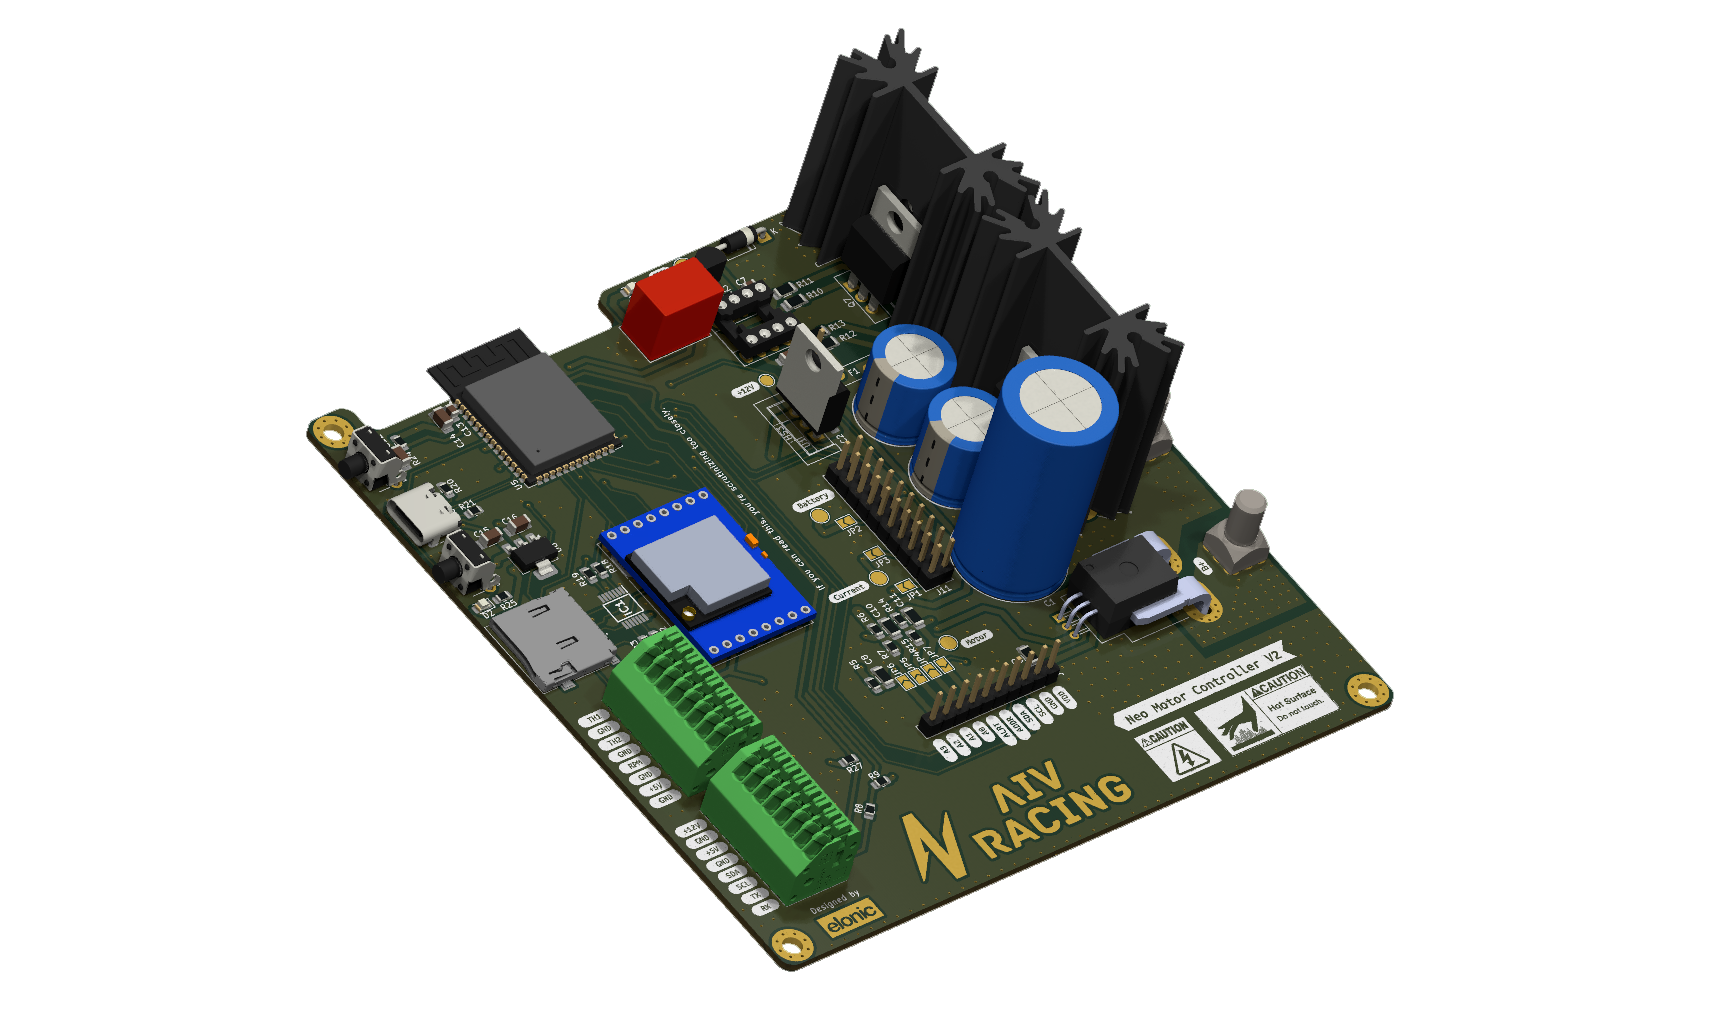
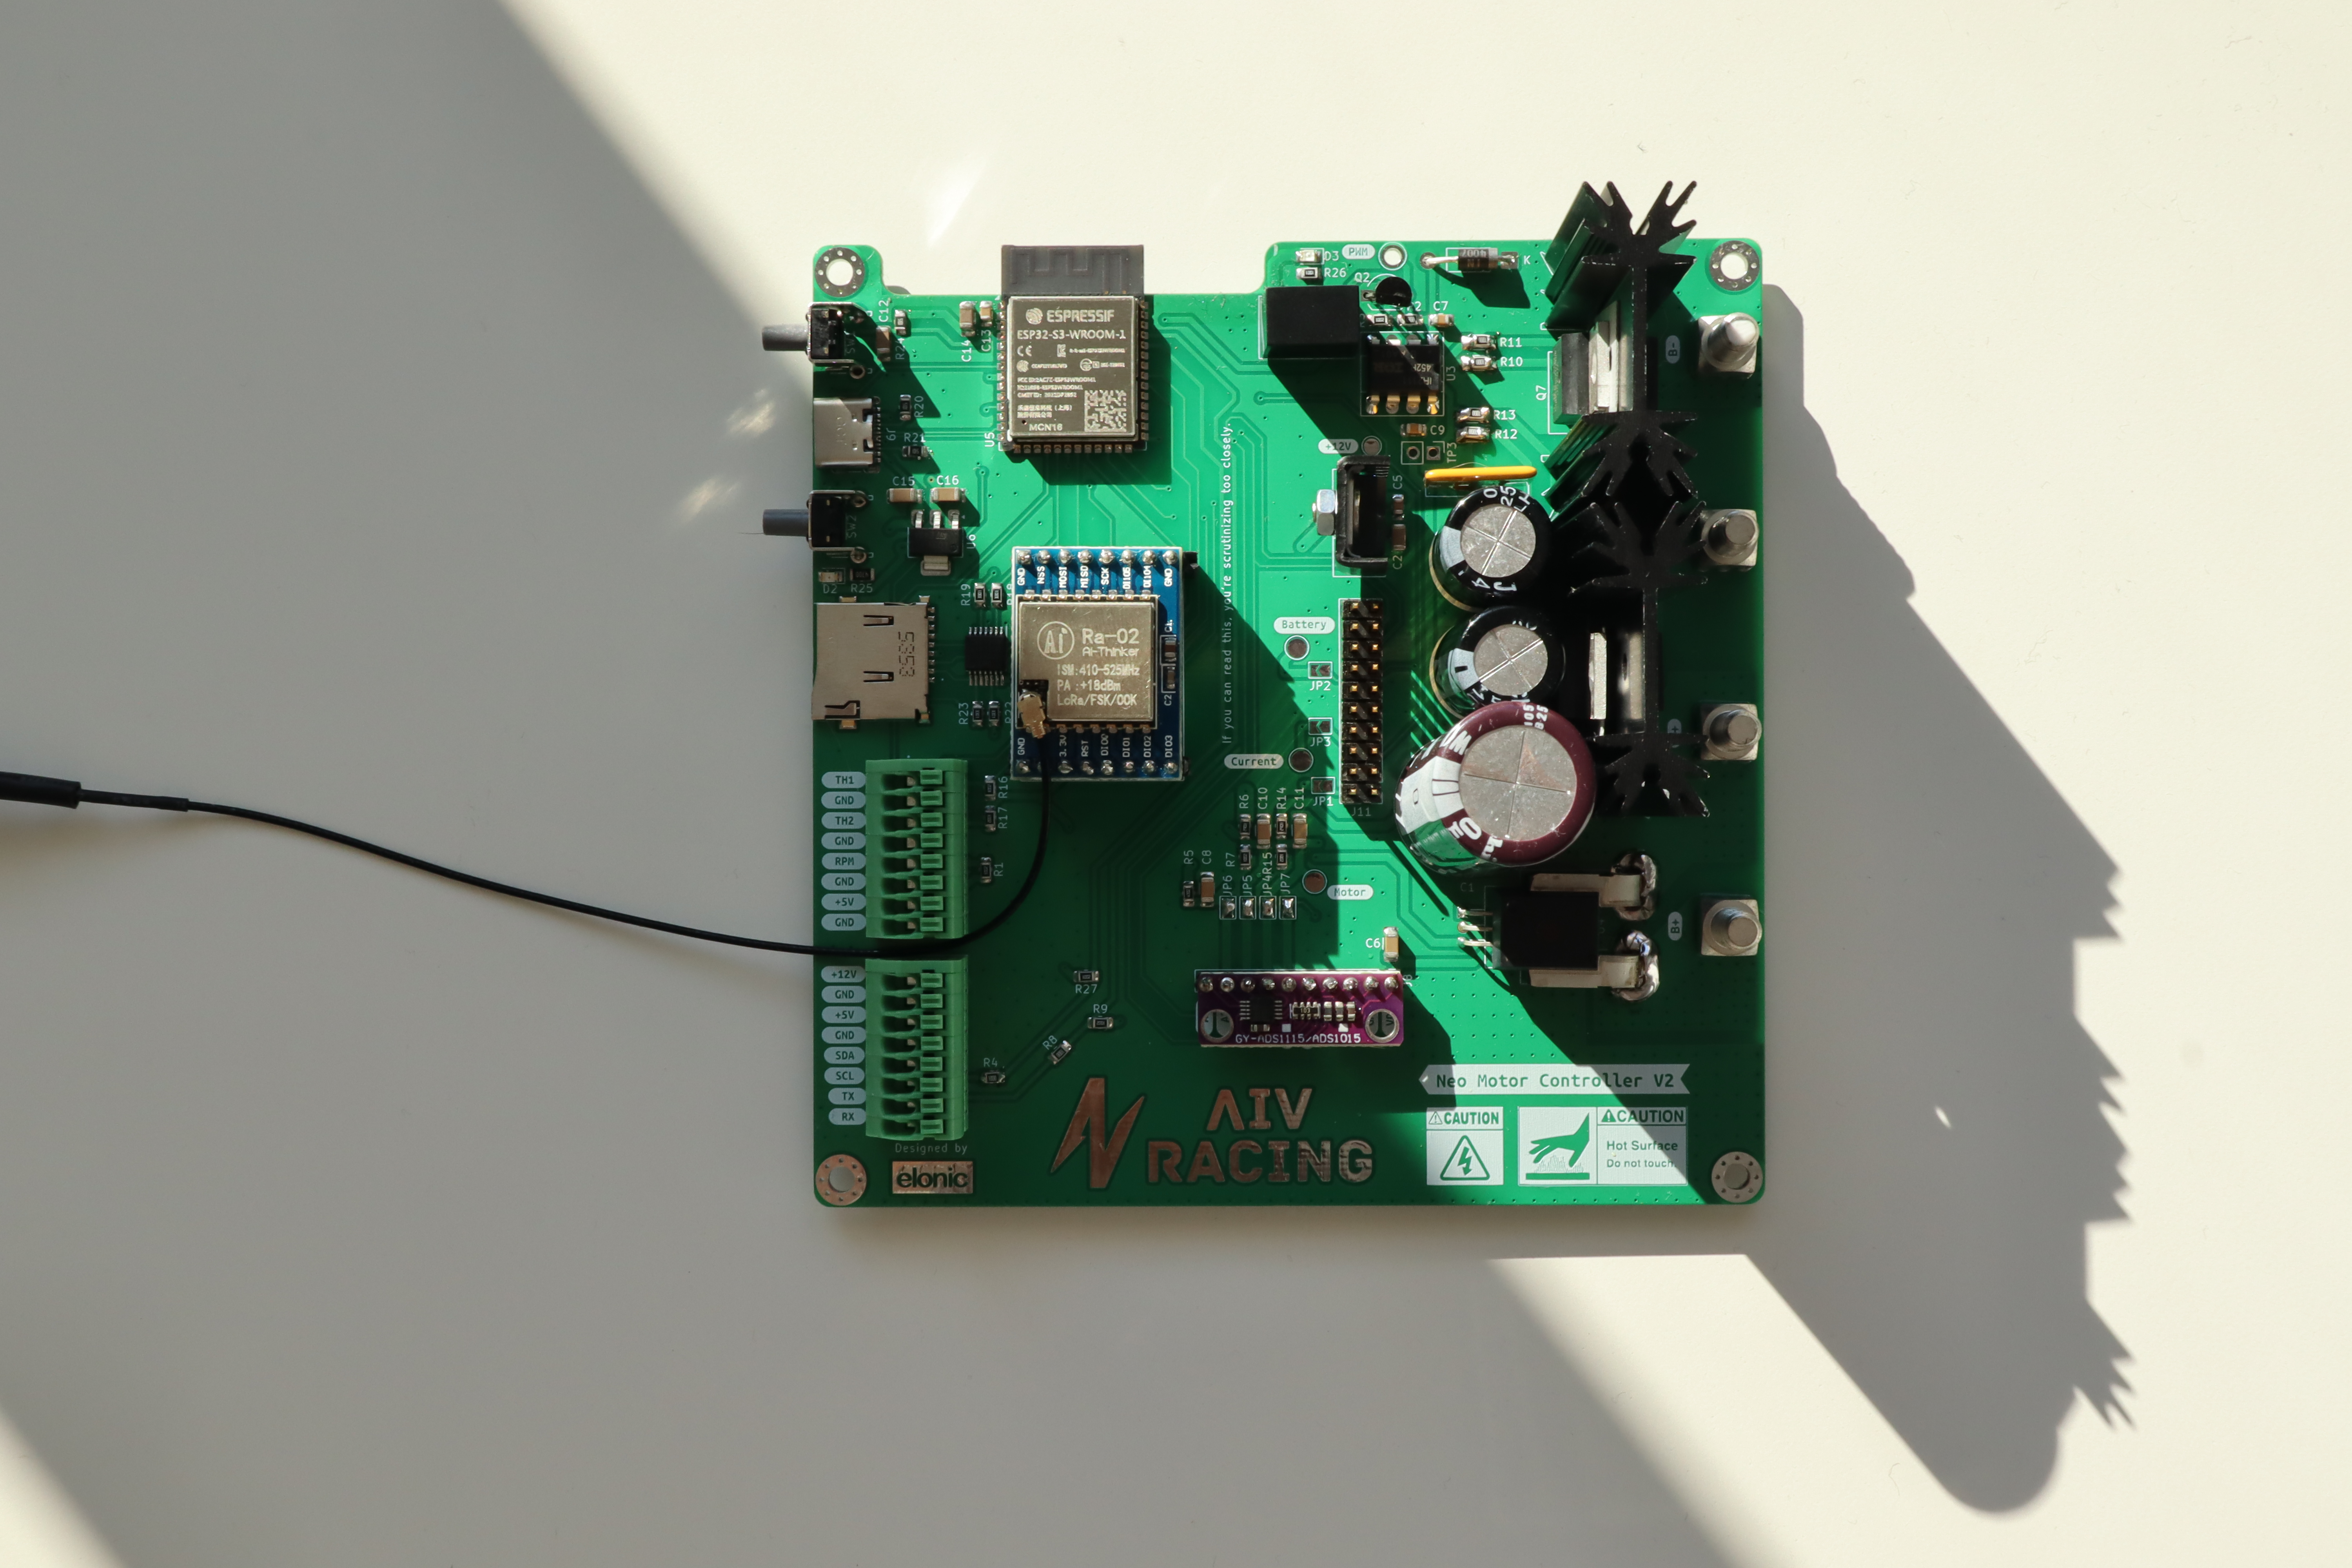
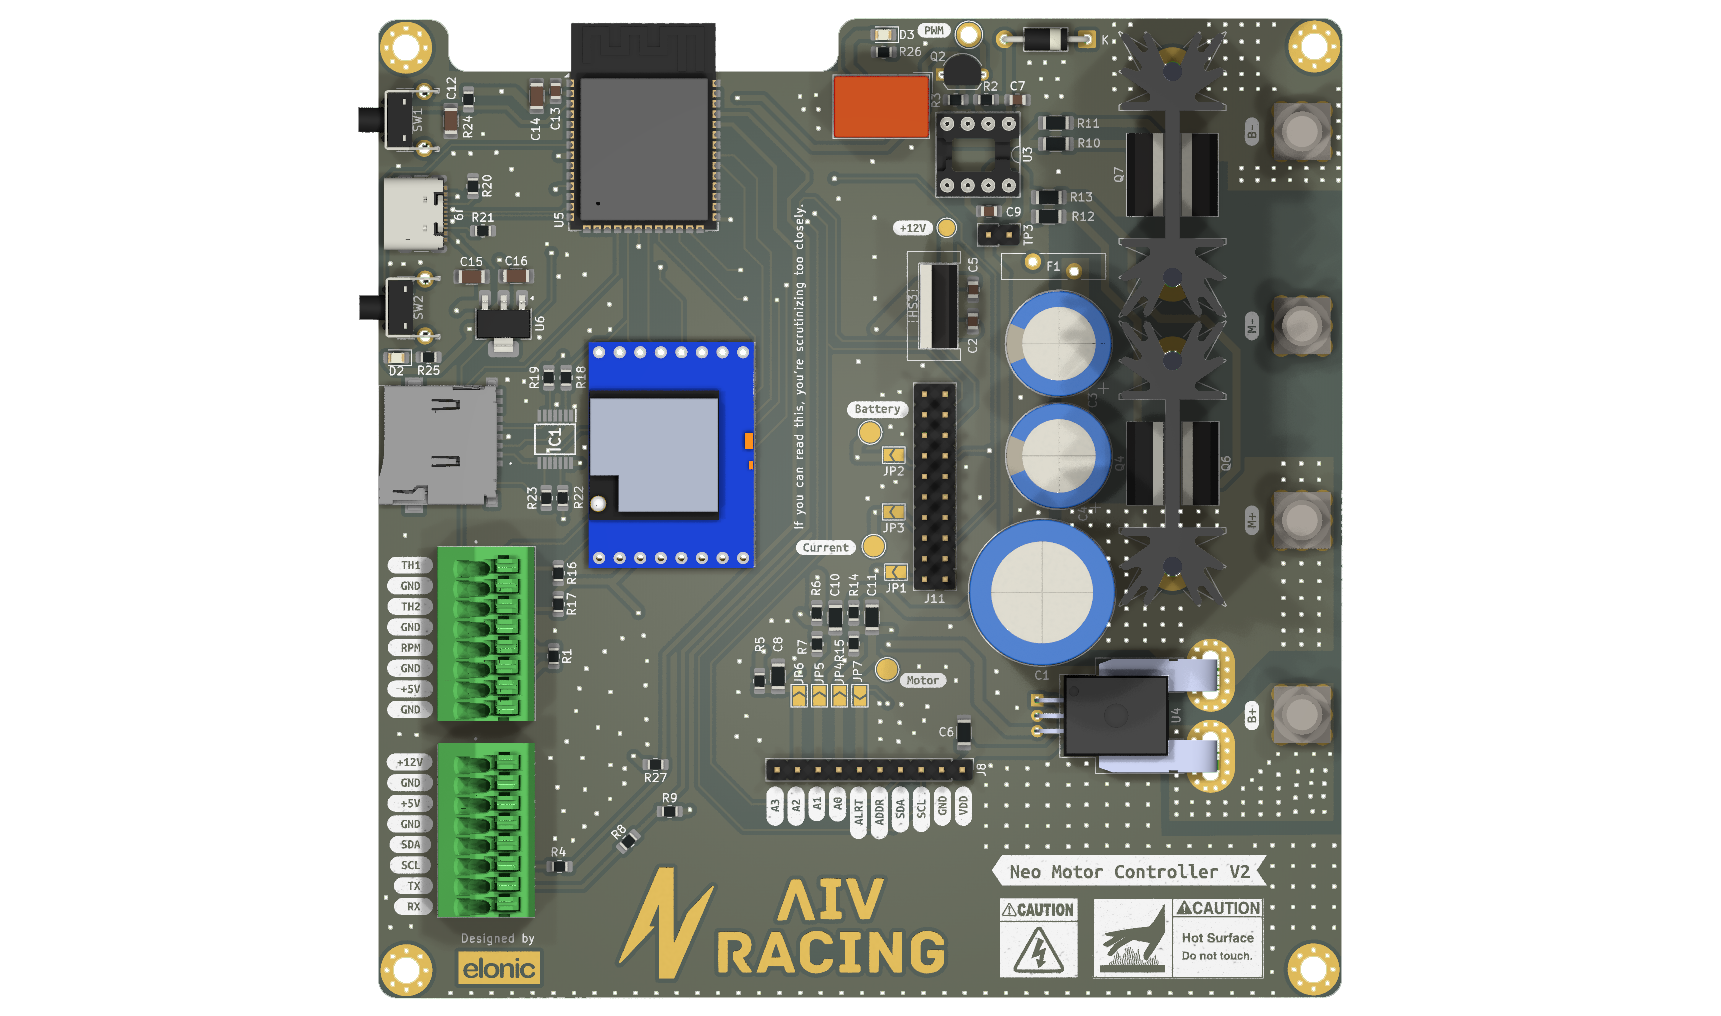
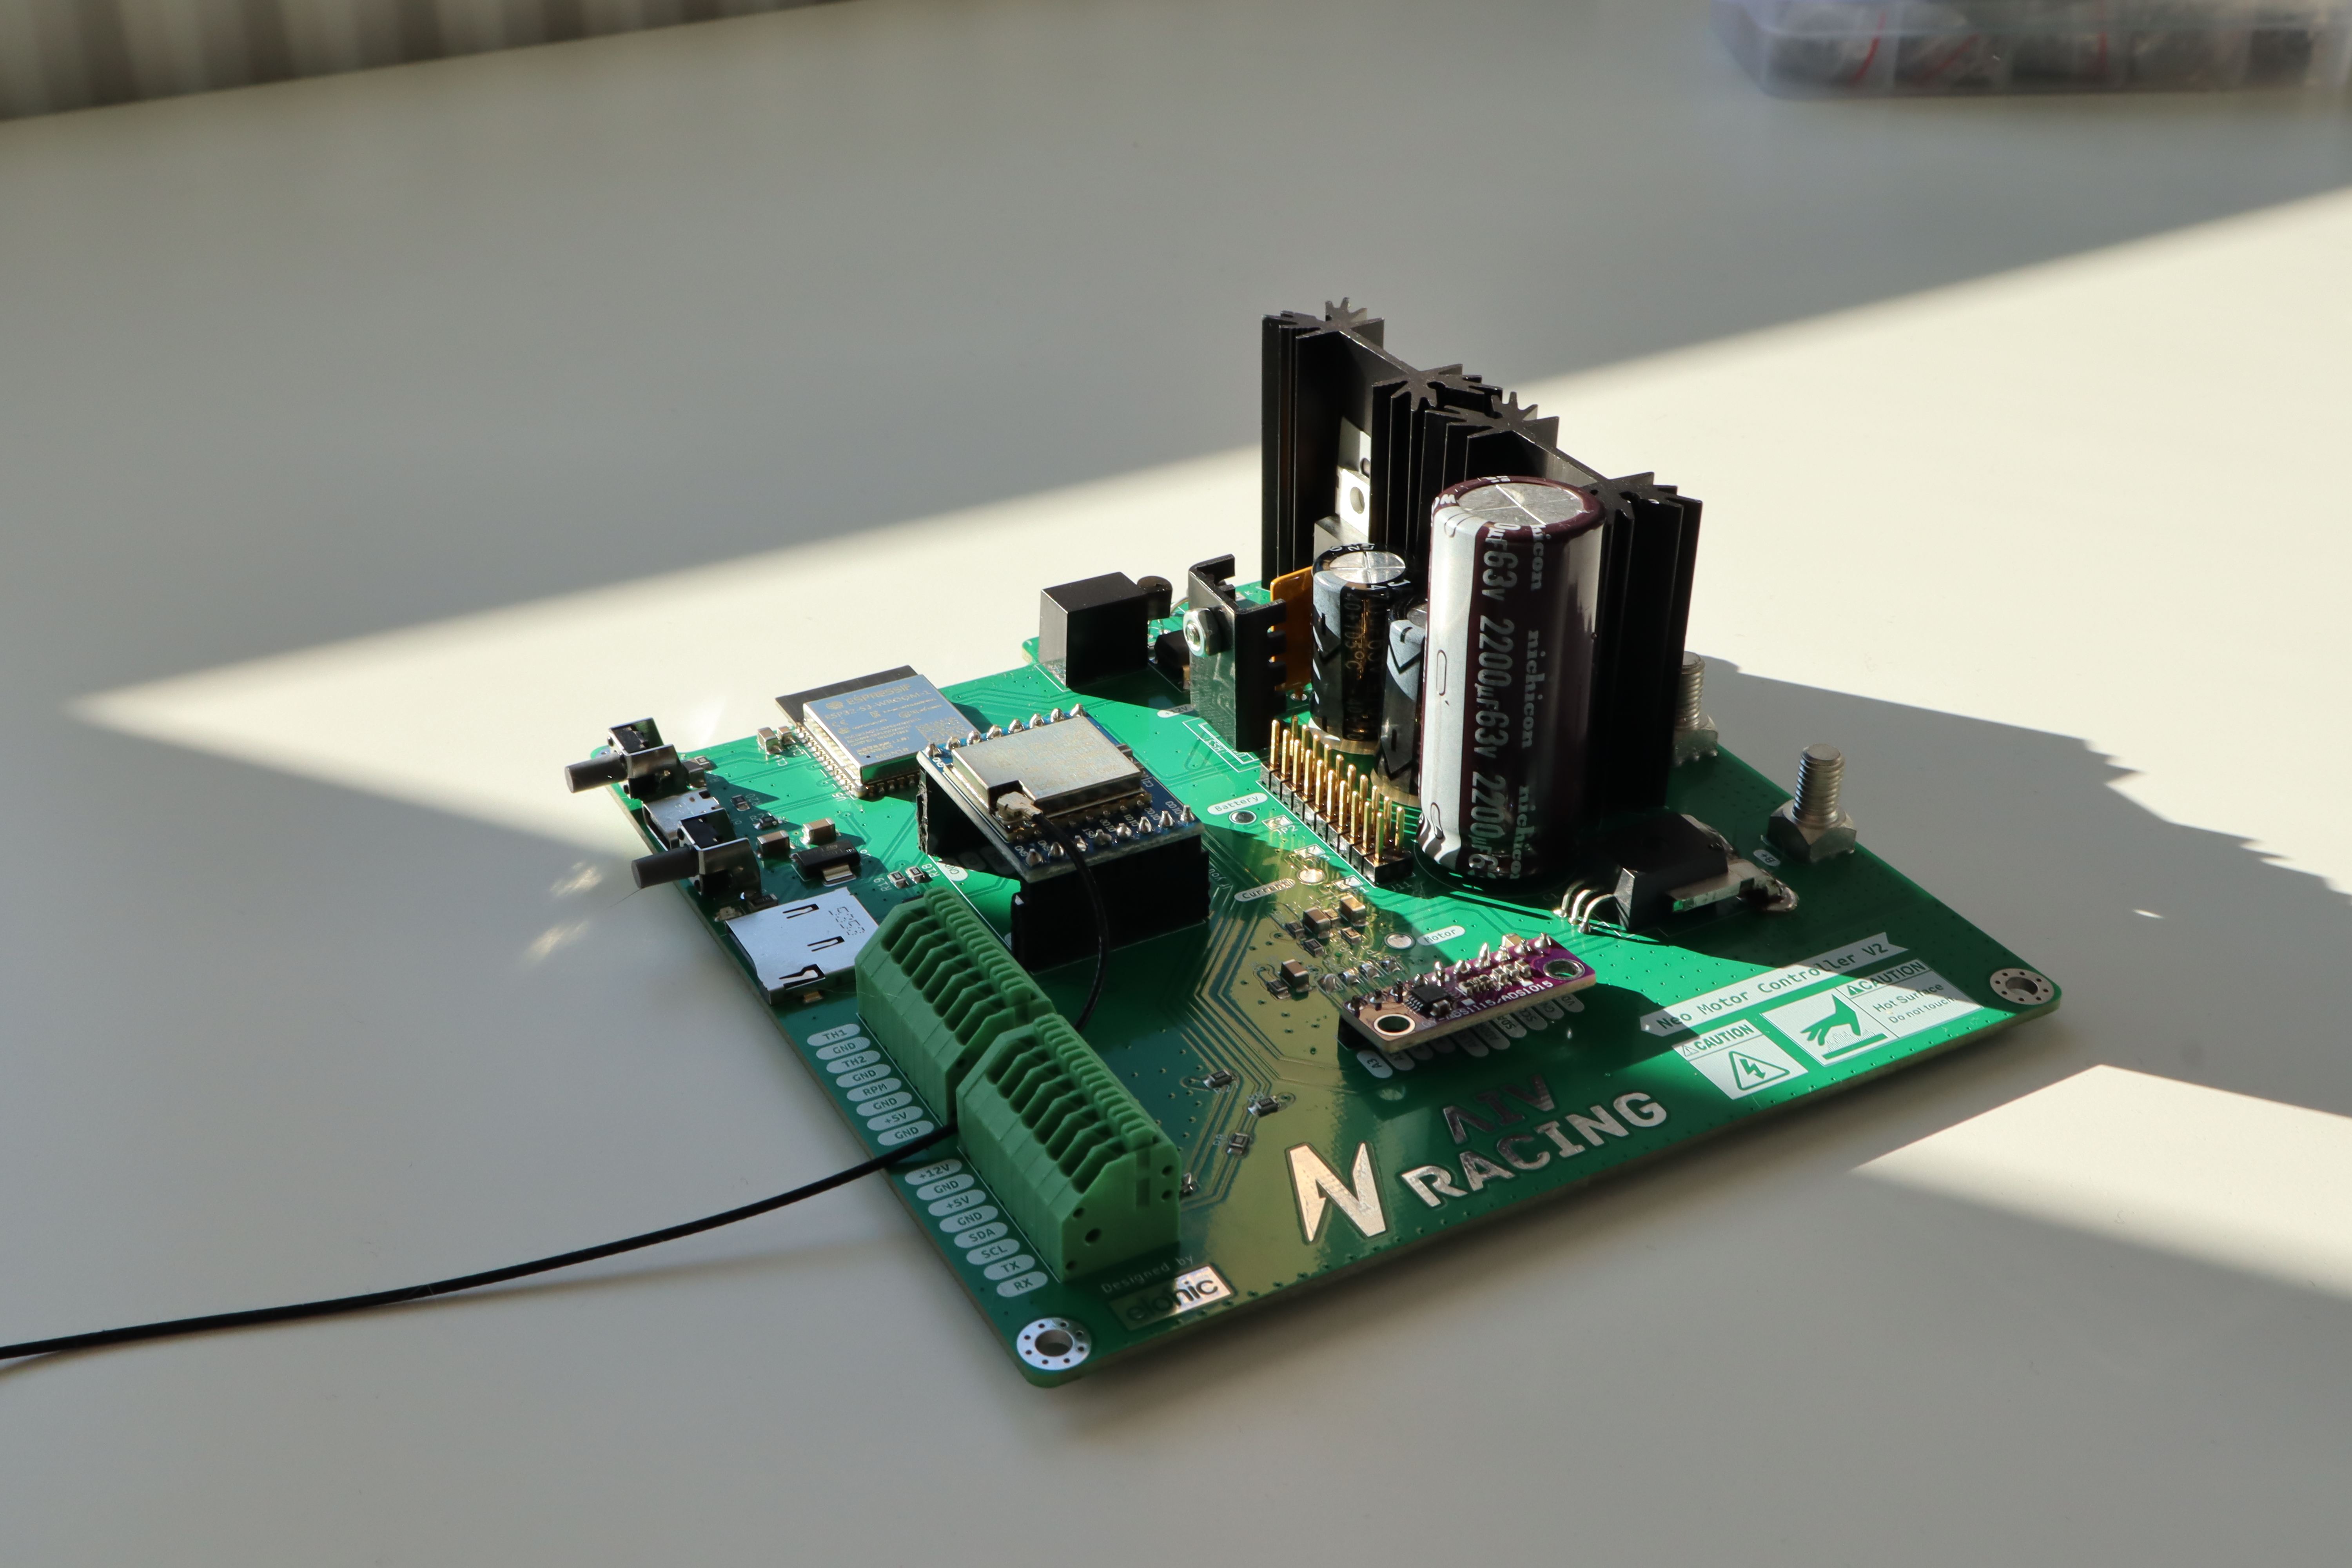
- Board 1 (Telemetry, Motor Control & Logging):
- Houses the core motor driver stages, high-frequency current sensing, and voltage monitoring to feed the real-time energy pacing calculations.
- Features an onboard high-speed MicroSD binary logger for post-session data analysis.
- Integrates a LoRa wireless transceiver to stream continuous battery health and race pace metrics straight to the pit wall.
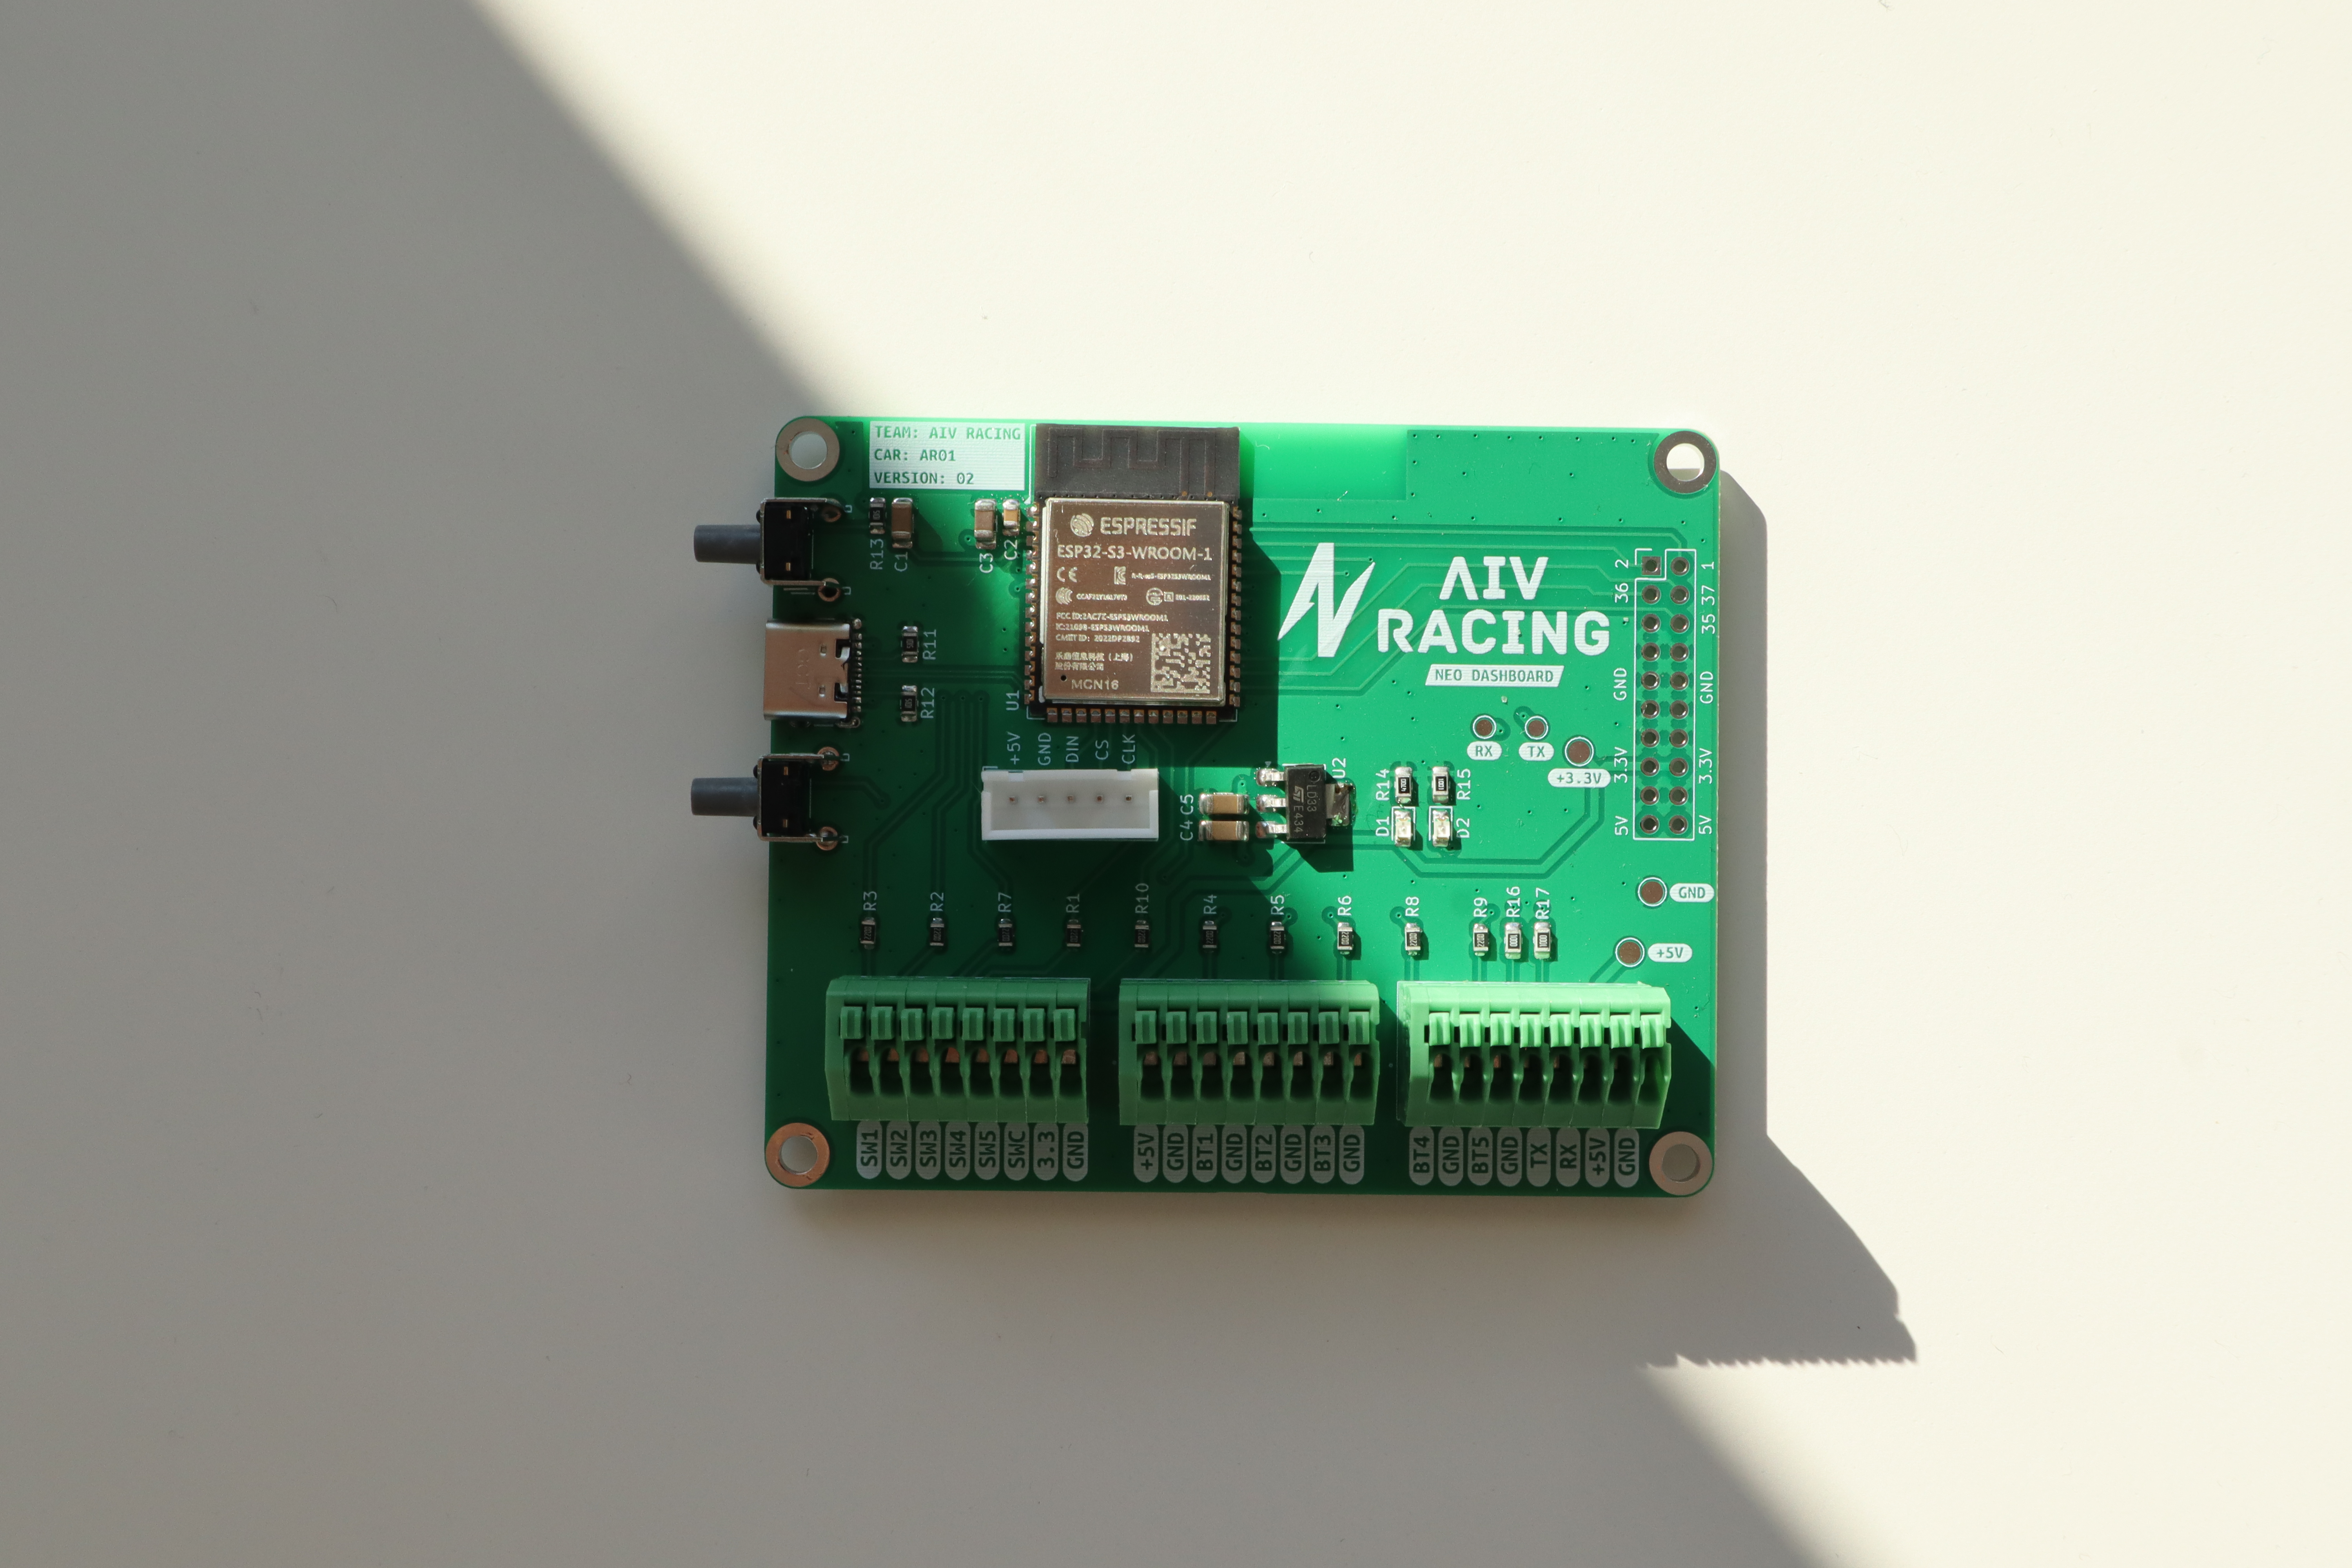
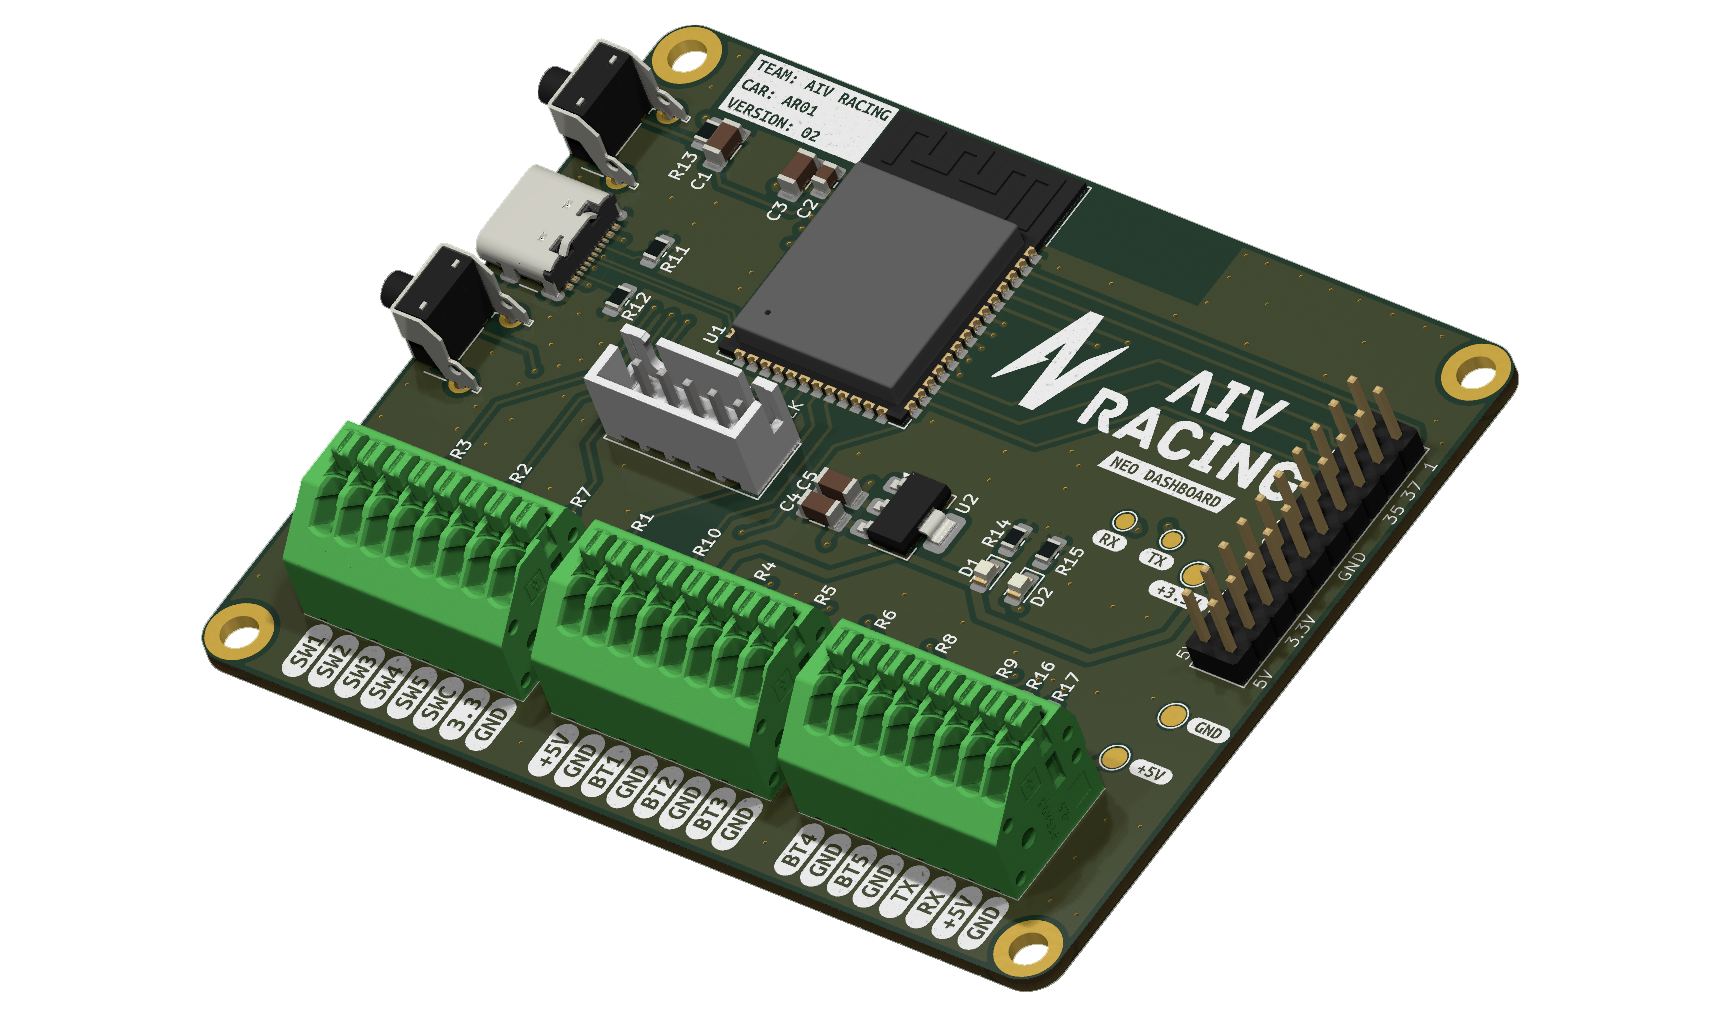
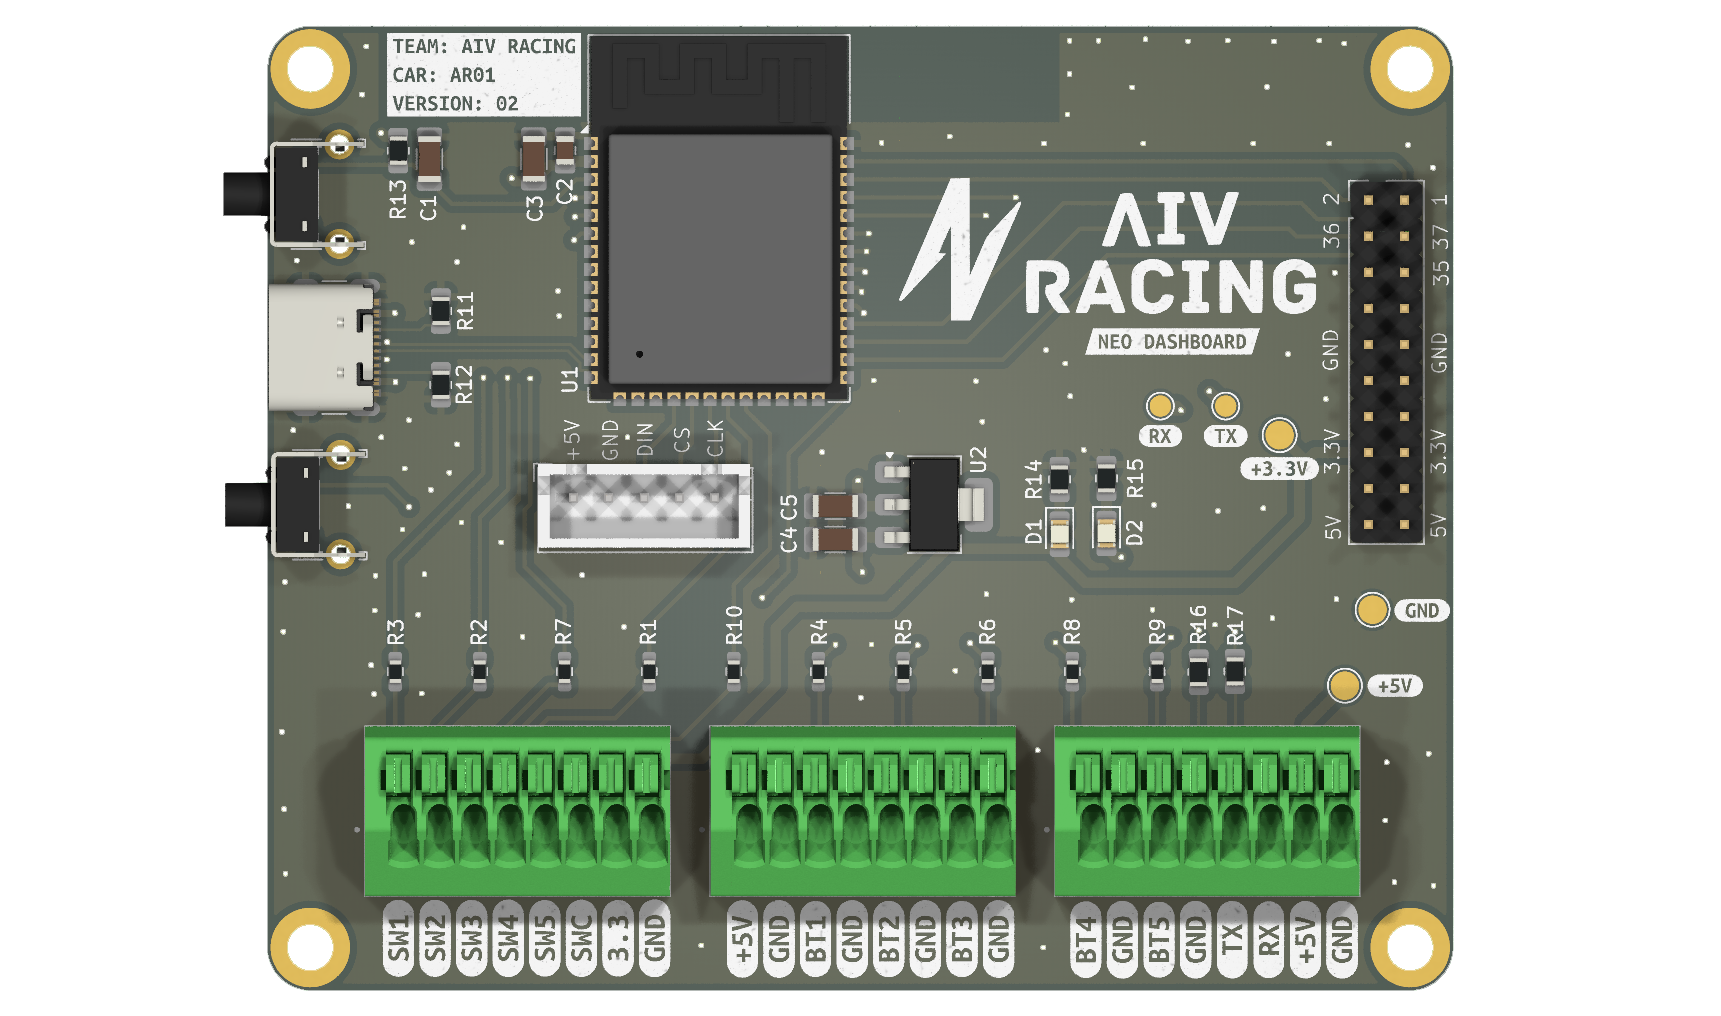
- Board 2 (Display, User Inputs & Cockpit Interface):
- Dedicated human-machine interface mounted in the cockpit for the driver.
- Manages real-time display feedback.
- Communicates seamlessly with the primary power node over the CAN bus, ensuring low latency and simple, reliable operation under race conditions.
Engineering Highlights
- Dynamic Energy Pacing: High-frequency current tracking feeds continuous power consumption calculations, allowing the team to dial in the exact speed required to use every available joule by the final lap.
- Turnkey Hardware Execution: Developed end-to-end—spanning architectural design, multi-layer PCB layout, embedded firmware, communication protocols, steering wheel mechanical design, enclosure design, physical packaging and integration.
Technical Specifications
- Architecture: 2-Board Distributed Setup (Power/Telemetry Node + Display/Input Node)
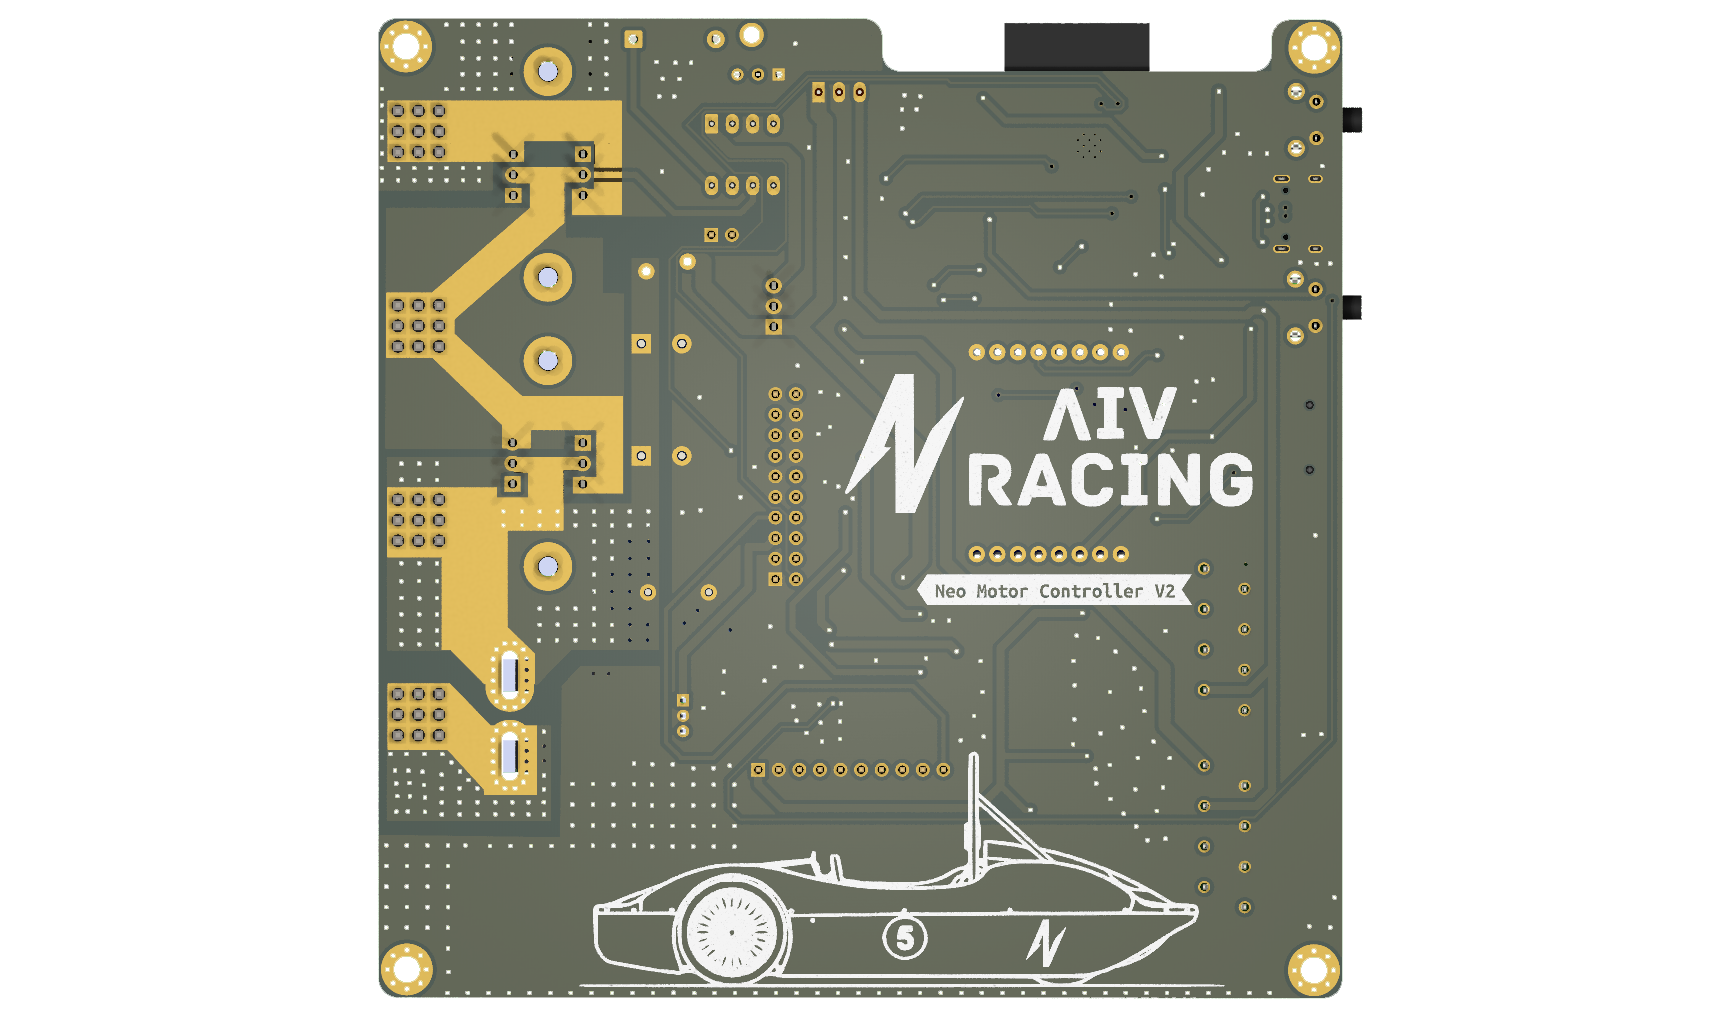
- PCB Stackup: 2-Layer Design Optimized for Cost Reduction & Manufacturability
- Bus Interface: High-Speed Differential CAN
- Telemetry: Long-Range (LoRa) Wireless Pit Stream & MicroSD Local Logging
- Control: Pwm Motor Control and real-time high-frequency voltage/current sensing for endurance energy pacing
- Target Application: Greenpower IET Formula 24+ EV Prototype